Photo of Khajani Sivapala

Khajani
Sivapala

Mechatronics Engineering
University of Waterloo

CURRENT POSITION

Tesla

Automation Engineering Intern

01 / EXPERIENCE

Experience

Automation Engineering Intern

Tesla · Sept 2026 – Present · Houston, TX

Show more
  • Developing first AI-integrated camera detection on 6 stations for foreign object debris (FOD), protecting $1.1M+ Megapack/escape.
  • Designing good/bad sample validation trials confirming FOD exceeds the AI camera's 5-pixel resolution minimum.
  • Designing, planning, and pitching a potential capital project investment, from CAD to senior engineering reviews.

Mechanical Lead

WATbotics, Robotics Design Team · Jan 2026 – Present · Waterloo, ON

Show more
  • Leading mechanical design for a 32+ member team, running SolidWorks design reviews from concept to prototype.
  • Optimized the quadcopter airframe for 18% higher strength-to-weight, with modular sub-assemblies for under 10 min field repairs.
  • Redesigned motor arms over 5+ finite element analysis (FEA) iterations, cutting stress concentrations.

Robotics Engineer

WATbotics · Sept 2025 – Jan 2026

Show more
  • Designed and modeled the quadcopter base and propellers in SolidWorks.
  • Helped develop the electrical schematic for component and power connections.
  • Created the full quadcopter assembly sketch integrating mechanical and electrical systems.

Engineering Analyst (Design & Automation)

Toyota Motor Manufacturing Corporation · Jan 2026 – Apr 2026 · Cambridge, ON

Show more
  • Implemented a PLC scan-verification interlock to halt defect propagation, eliminating 30 min/vehicle of rework and ~$750K output risk per occurrence.
  • Led failure analysis on a driveshaft press, isolating spring stiffness as the root cause and redesigning to cut faults by 70%.
  • Redesigned the structure of a $25K, 36-unit pallet array from root cause findings, cutting repeat failures ~30%.
  • Applied DFM/DFA to redesign a conveyor skate in SolidWorks, cutting removal time 70% with quick-release fastening.

Aerodynamics General Member

UW Formula Electric · Jan 2025 – Jan 2026

Show more
  • Developed a carbon fiber undertray, improving structural performance.
  • Fabricated a 260" × 180" vacuum bag to enable consistent curing.
  • Supported aerodynamic component testing and manufacturing prep.

Chassis General Member

UW Formula Electric · Sept 2024 – Jan 2026

Show more
  • Ran adhesive tests to optimize steel chassis bonding.
  • Machined chassis components to tight tolerances.
  • Processed 20+ steel tubes and assembled the chassis frame.

Maintenance Engineering Intern

Cérélia North America · Jun 2025 – Aug 2025 · Mississauga, ON

Show more
  • Troubleshot recurring sensor faults on PLC-controlled equipment, cutting repeat failures ~20%.
  • Engineered digital inventory tracking (CMMS) for 2,900+ parts, cutting retrieval time ~60% to speed repairs.

First Year Representative, Mechatronics Engineering

Waterloo Engineering Society · Sep 2024 – May 2025

Show more
  • Advocated for Mechatronics students and helped improve course delivery.
  • Analyzed student surveys, contributing to an improvement in class performance of about 30%.

Medical Administrative Assistant, Biomedical Engineering

Scarborough Health Network (Co-op) · Feb 2023 – June 2023 · Scarborough, ON

Show more
  • Assisted BME technicians with diagnosing and repairing neonatal incubators.
  • Uploaded 25+ equipment data sheets and edited floor plans to update the hospital database.
  • Organized and proofread technical documents to improve accuracy.

02 / PROJECTS

Projects

Click any project to open its photos and videos.
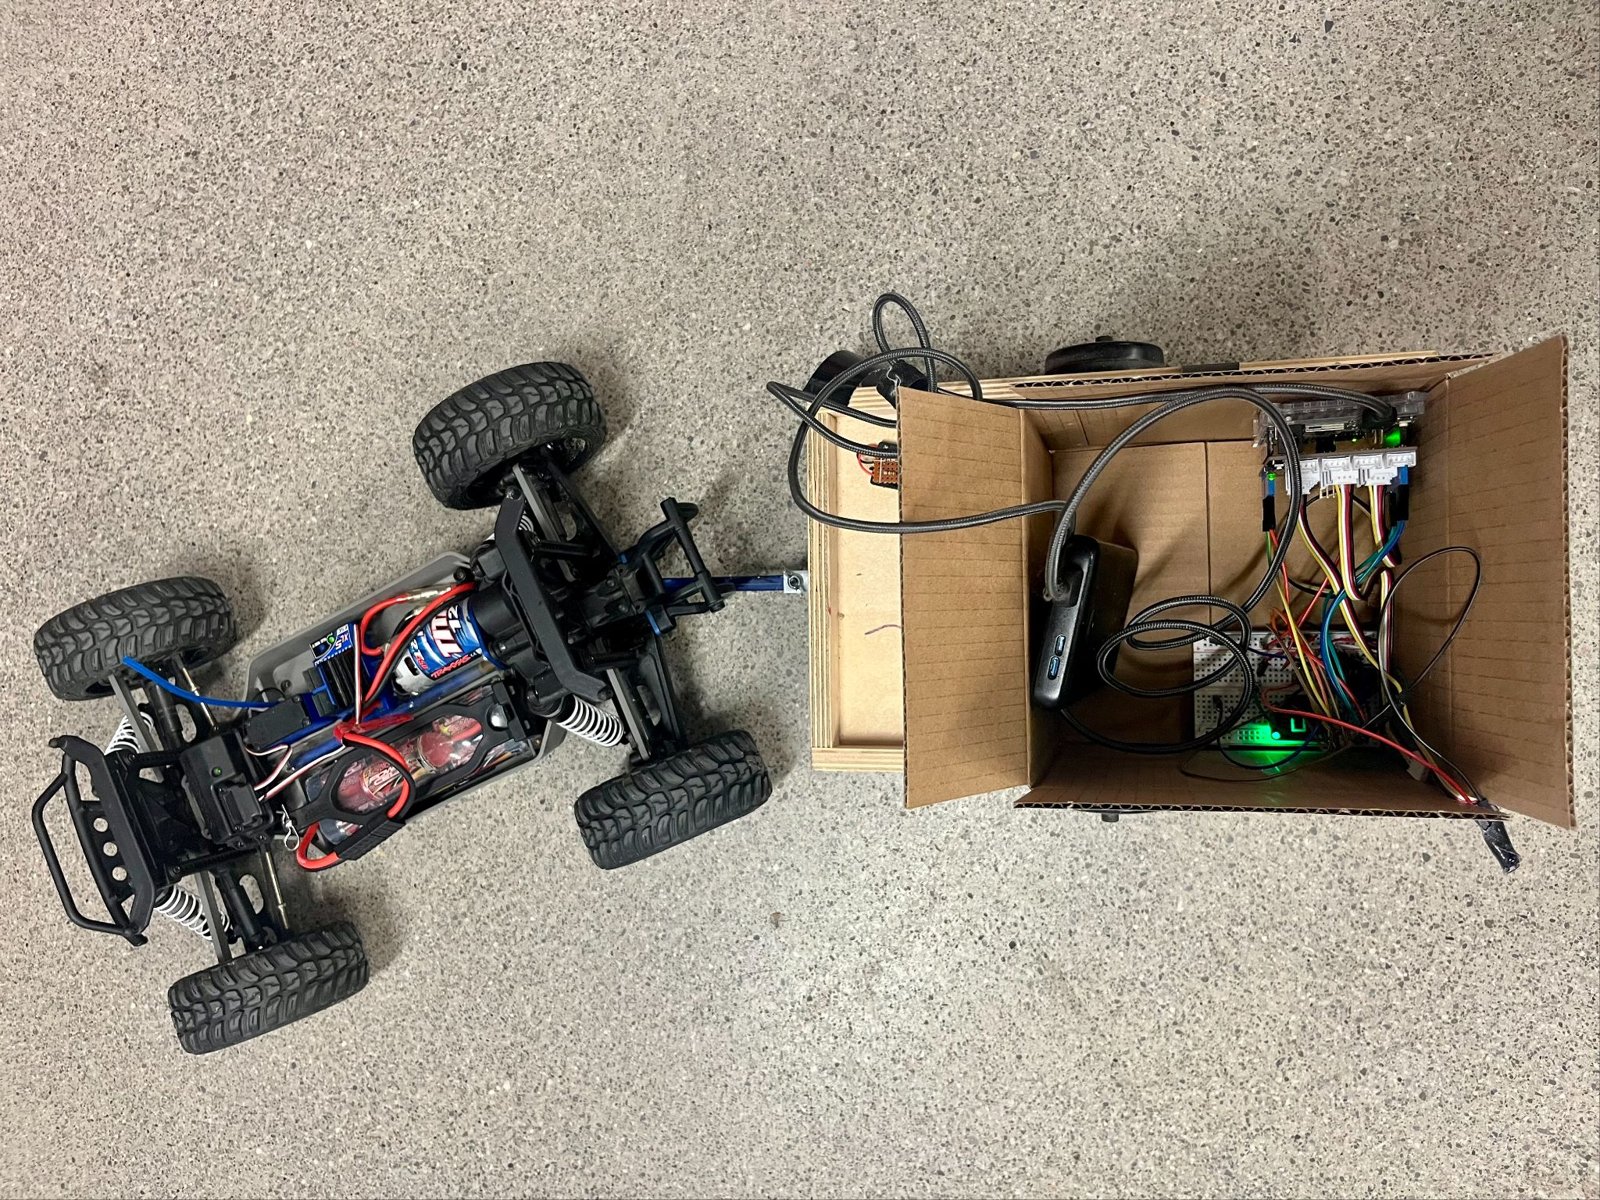
Telligence hazard detection prototype on a test vehicle

Canadian Nuclear Laboratories Innovation Challenge (Feb 2026)

#1 Best ExecutionEmbedded SystemsSensor FusionIoTC++ FirmwareAlert Logic

Telligence: Hazard Detection

Integrated IMU, magnetometer, temperature/humidity, IR, and touch sensors into one hazard score, detecting 7/7 simulated hazards. A two-layer alert logic sends a 3 g+ crash to a critical LCD and buzzer warning in about 3 s. Non-blocking C++ firmware streams 8 channels every 5 s to off-site responders.

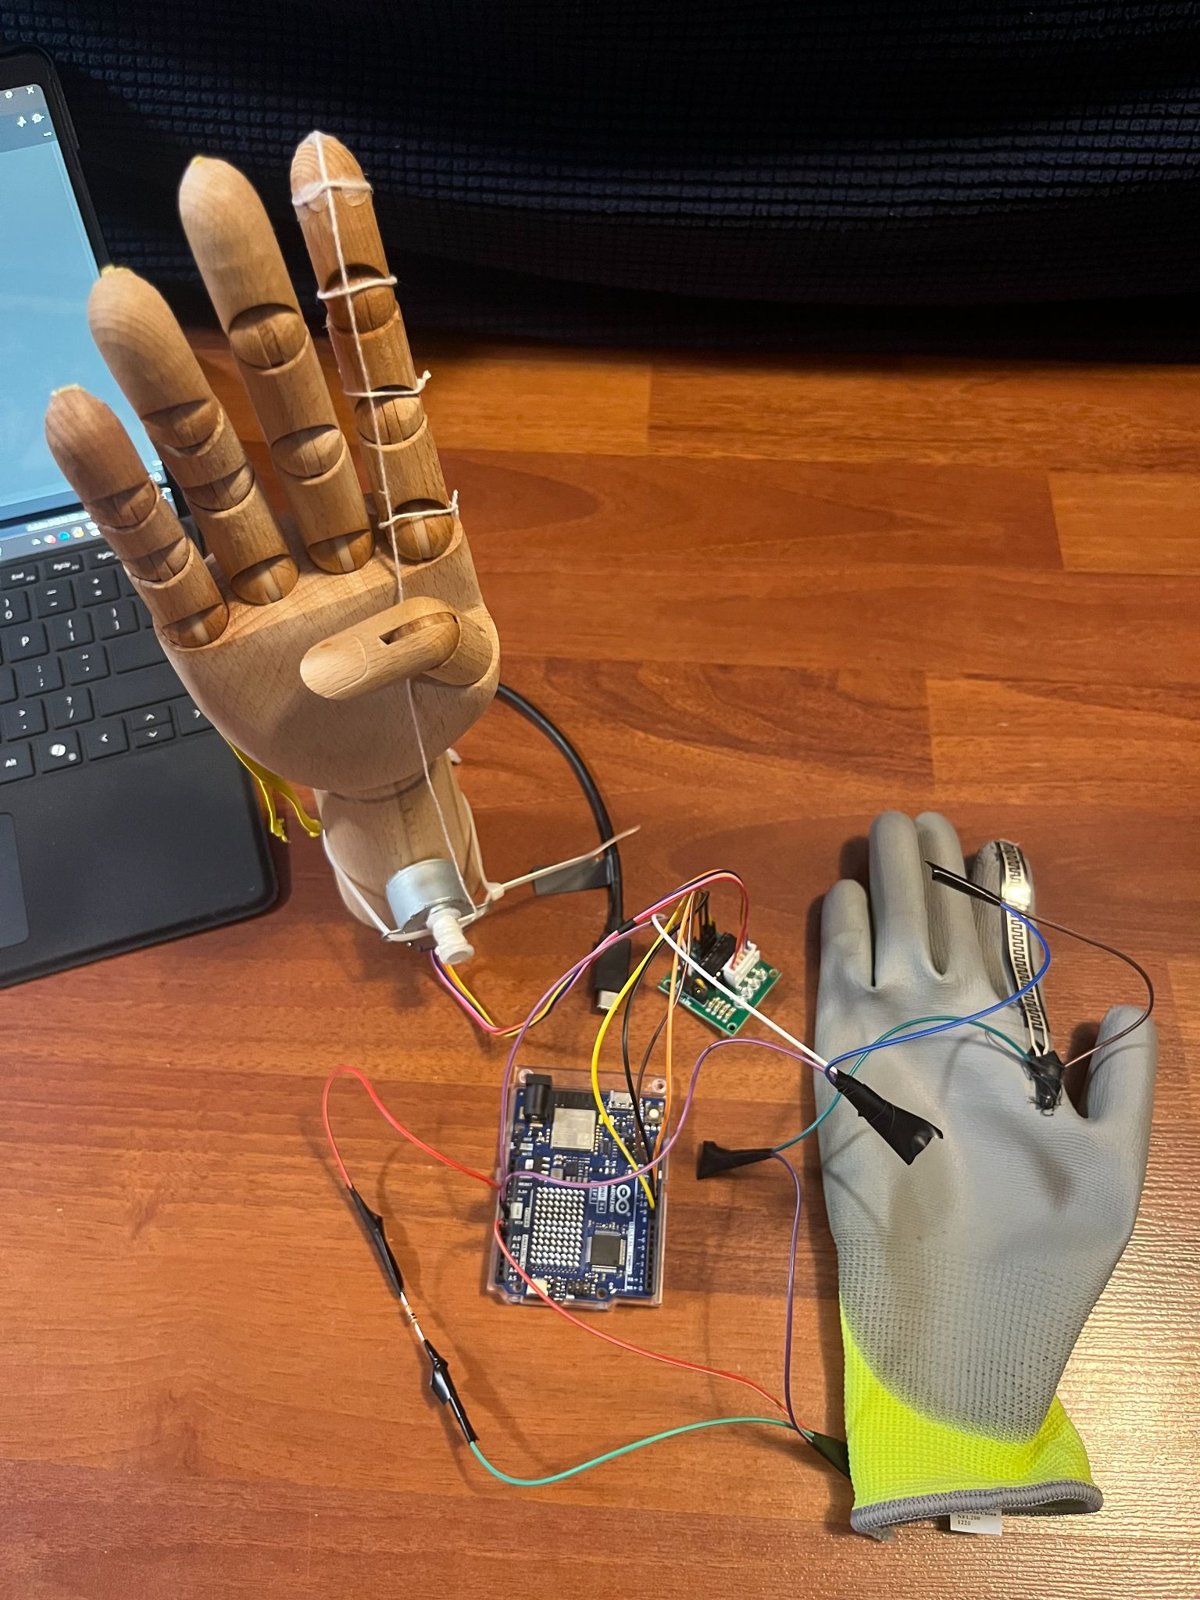
ReFlex glove and teleoperated robotic hand

BiomechatronicsWearable SensingHMIArduinoServo ControlTendon-Driven

ReFlex: Teleoperated Robotic Hand

Independently built a teleoperated robotic hand with custom flex-sensor mapping that mirrors operator gestures at 90% accuracy and under 500 ms delay. Designed the servo-actuated, tendon-driven finger mechanism through 4+ iterative prototypes.

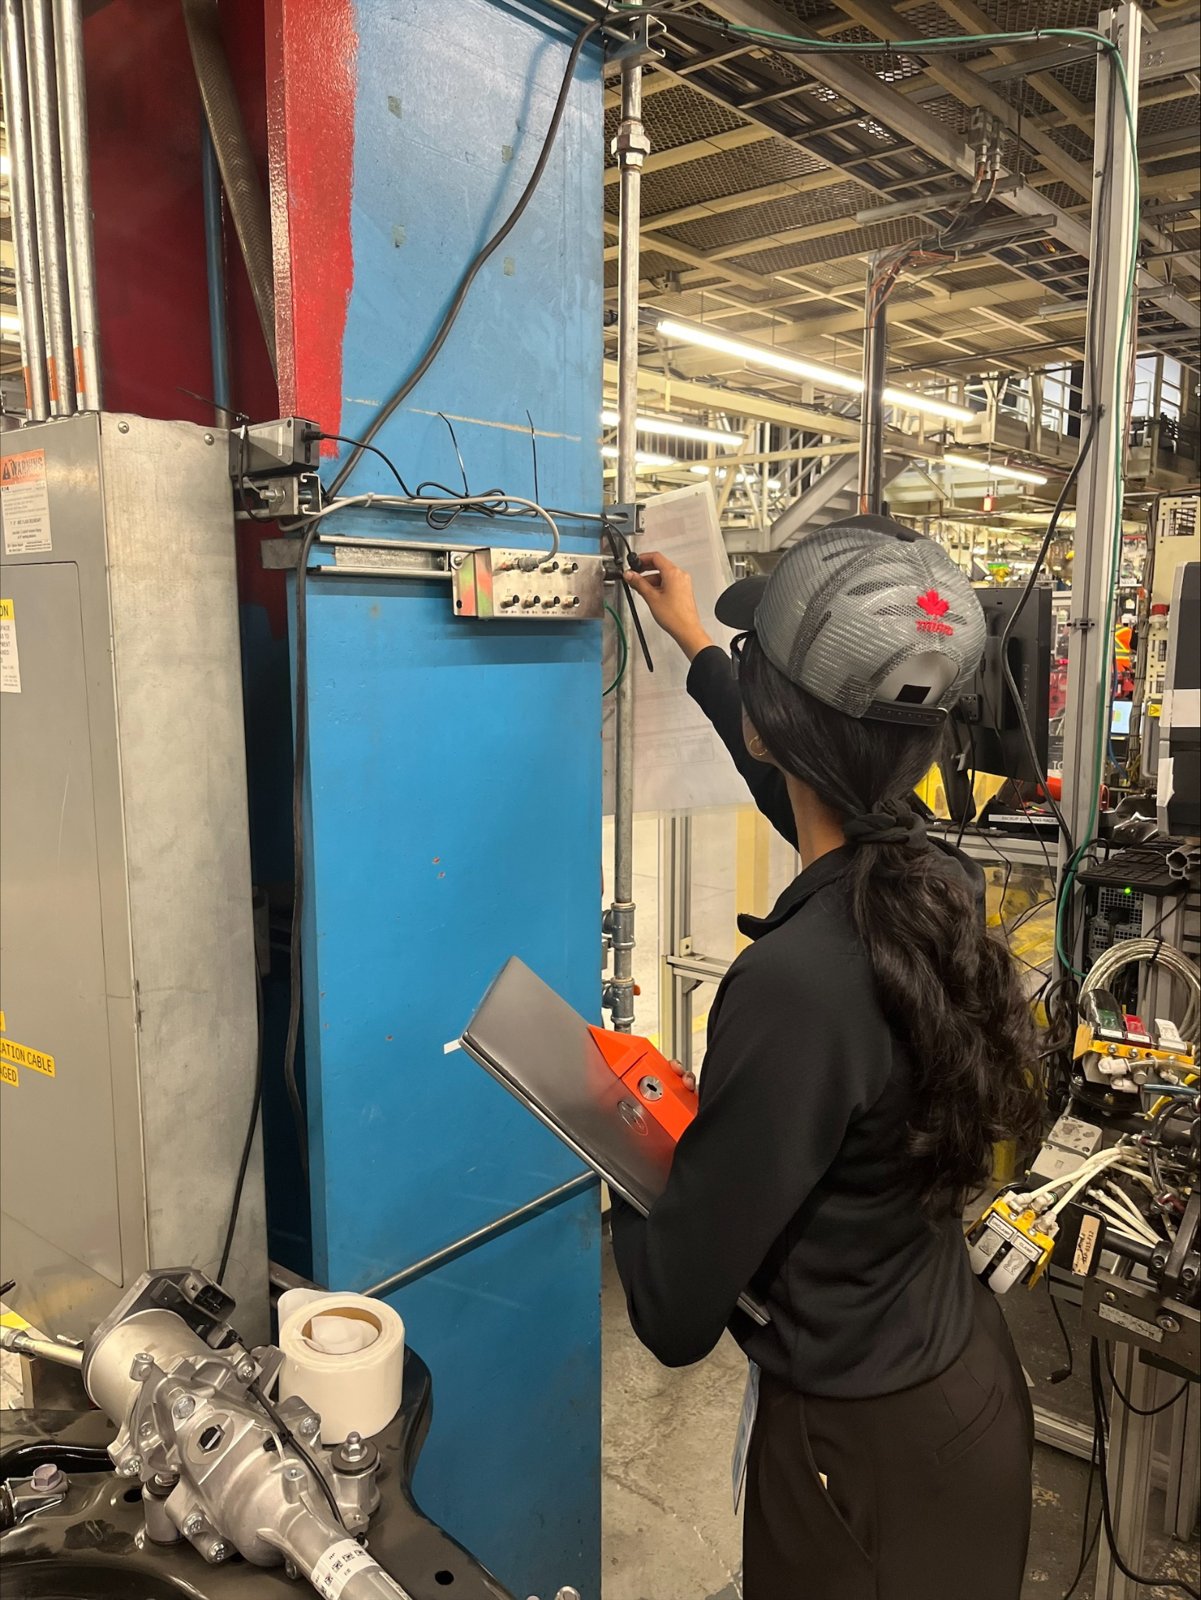
Working at the PLC control panel at Toyota

Toyota Motor Manufacturing Co-op (Jan – Apr 2026)

PLC Ladder LogicFail-Safe DesignInterlock LogicControl SystemsSensor & Barcode IntegrationRoot Cause Analysis

Toyota: Fail-Safe Quality Control

Engineered a fail-safe verification gate in the PLC logic so the process only advances once a barcode scan confirms the part, blocking wrong-part errors at the source. Eliminated 30 min/vehicle of rework and ~$750K of output risk per occurrence. Owned the hardware build: sourced parts, wired the full I/O block, and integrated the scanner, interface box, and pushbutton into one controller.

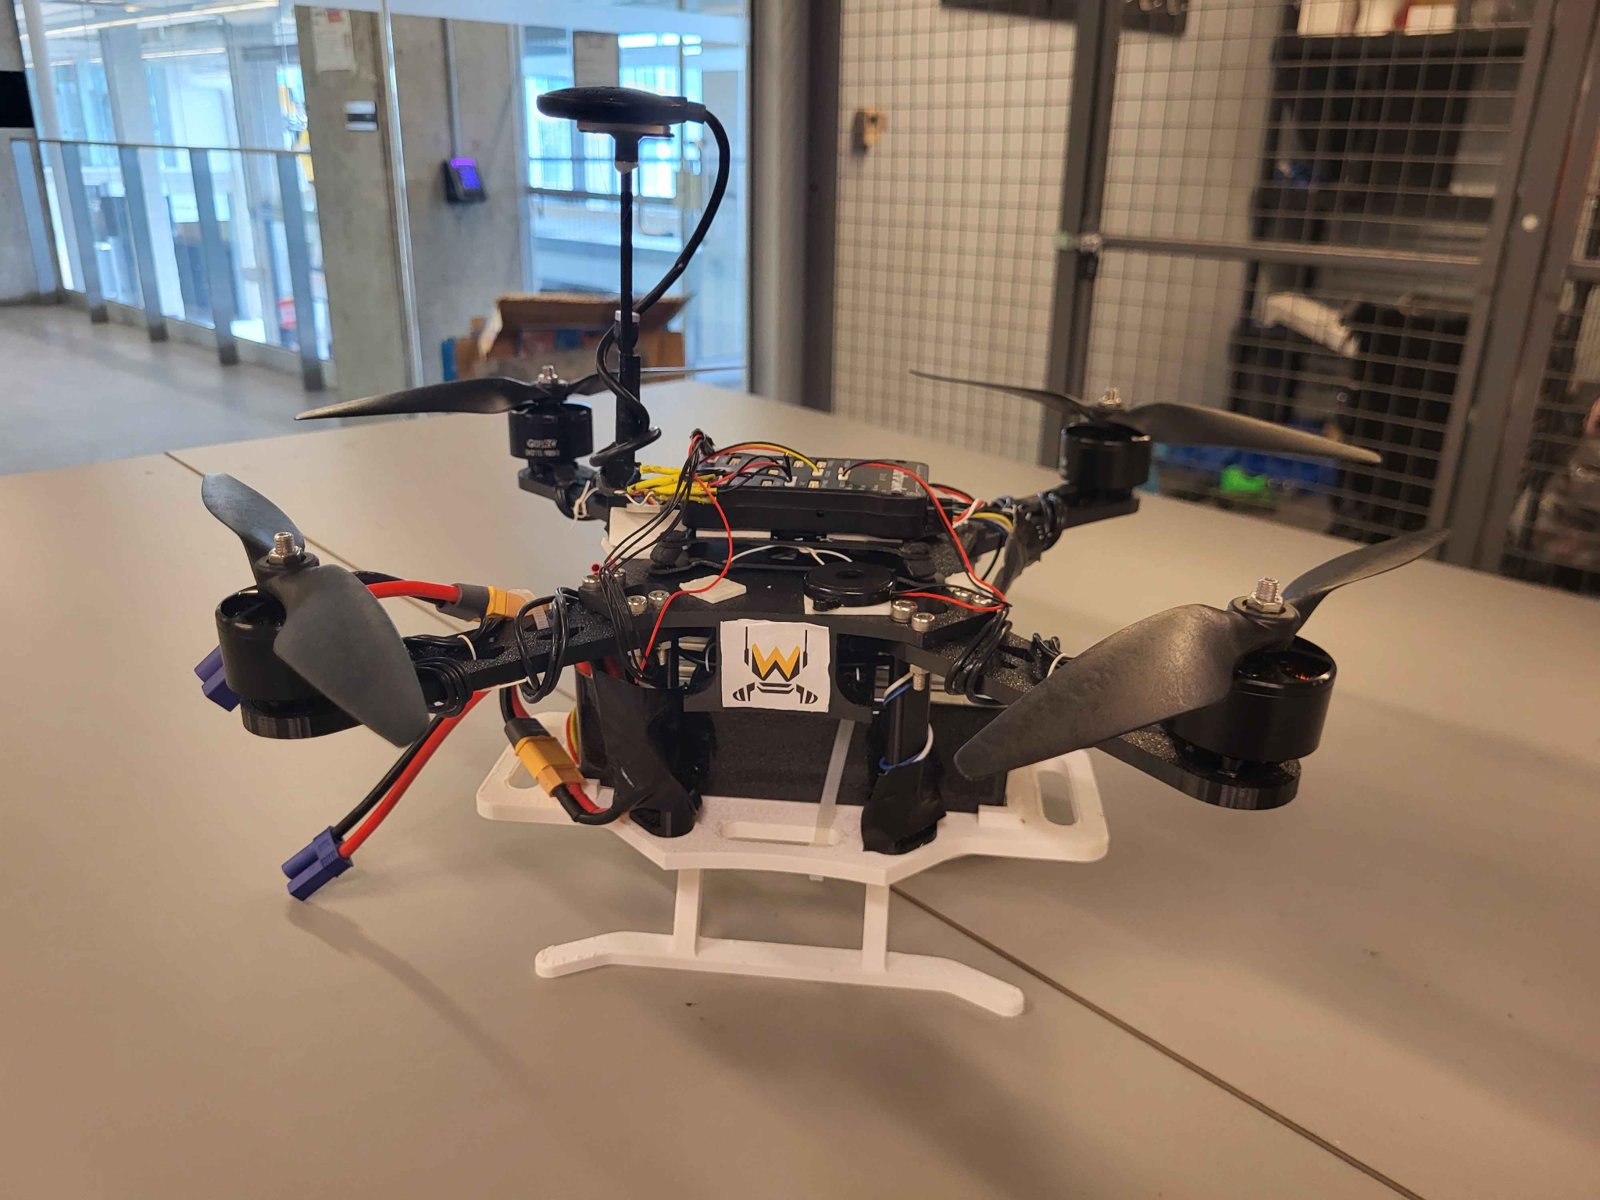
Assembled WATbotics quadcopter

WATbotics Robotics Design Team (Jan 2026 – Present)

SolidWorksFEAModular DesignStructural OptimizationElectromechanical IntegrationPixhawk Flight Controller

Quadcopter: Modular Airframe Design

Mechanical lead on a quadcopter built from scratch. A modular airframe with separate arms and plates lets any sub-assembly be swapped in under 10 minutes, and 5+ FEA-informed iterations delivered an 18% strength-to-weight gain. Co-planned the wiring architecture around a Pixhawk flight controller, ESCs, GPS, and a telemetry link.

DotMatic braille printer

Assistive TechnologyRapid PrototypingMotion ControlLEGO EV3Encoder Feedback

DotMatic: Braille Printer

Developed a 3-axis assistive braille printer that converts text files to tactile braille for children, versus $2K+ commercial embossers. Achieved 95% dot depth and readability at 2.5 mm pitch using 1° encoder control and row-by-row printing.

Automated guided vehicle design

Toyota Mechanical Innovation Challenge (May 2025)

Mechanical DesignSolidWorks3D PrintingDC Motors & ServosSensors

AGV Design

Designed an automated guided vehicle for dual-mode door and box transport with safe warehouse navigation. Modeled and 3D-printed custom grippers in SolidWorks, and built a lift system with Tetrix, DC motors, servos, a PS4 controller, and sensors.